
Researchers create robotic hand that walks on its fingers using AI
ETH Zurich has developed a disembodied robot hand controlled by neural networks that can crawl forward, right itself when tipped over, and manipulate objects. The project demonstrates how AI-trained software could enable specialized tasks in robotics.

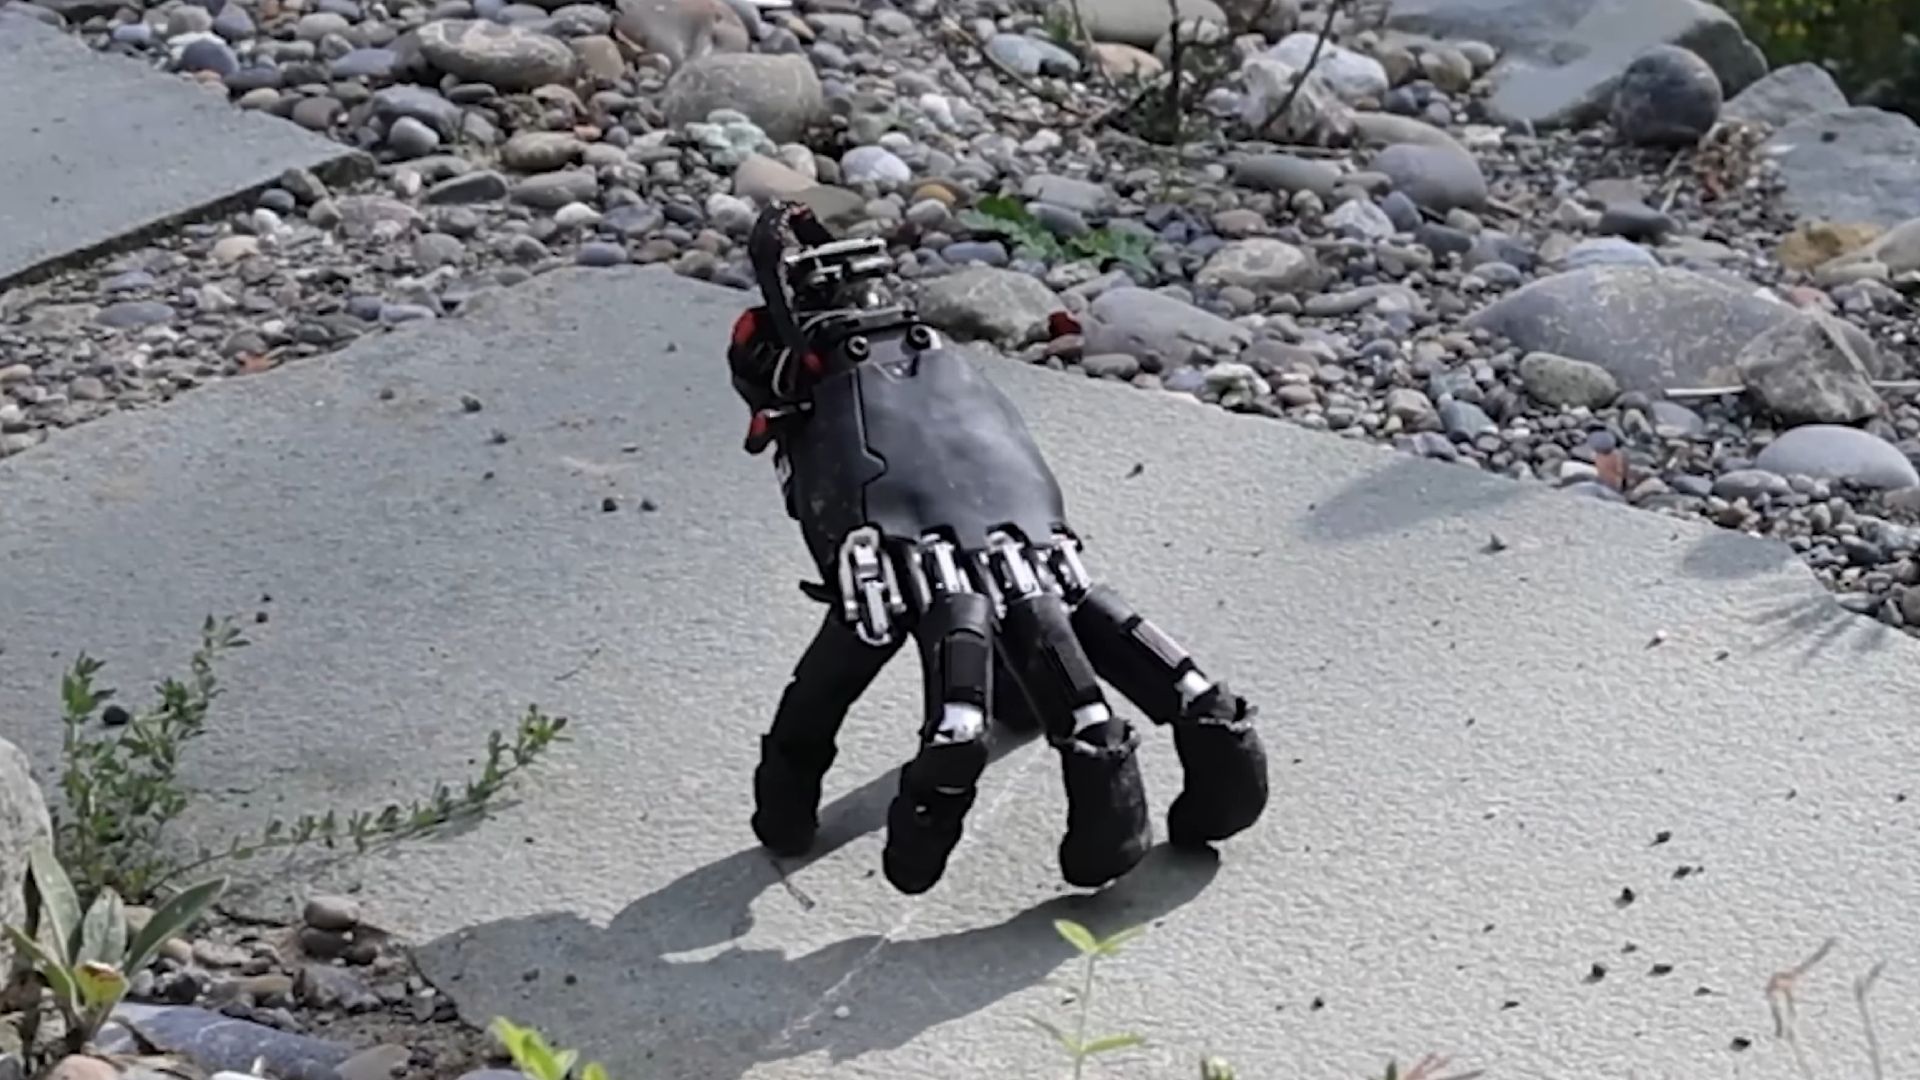
Researchers at ETH Zurich have created a robotic hand capable of independent locomotion, answering an unconventional engineering question: can a detached robot hand move on its own?
The hand features four joints per finger and moves using software trained through reinforcement learning in a simulator. A neural network iteratively determines joint positioning based on previous movements, allowing the hand to shuffle forward in a spider-like gait.
Beyond basic walking, the hand demonstrates additional capabilities. It can right itself when tipped over, push small objects, and press keyboard buttons. These functions hint at practical applications where large robots could deploy a specialized hand to reach distant locations their bulky frames cannot access.
The control system uses neural networks trained via reinforcement learning, which enables the hand to develop its shambling locomotion pattern through iterative learning. The YouTube demonstration video accompanying the project shows the hand in motion, with results that researchers acknowledge have generated significant online interest.
The project sits at the intersection of robotics innovation and AI development, showcasing how machine learning can solve unconventional engineering challenges in ways traditional programming might not easily achieve.
Sources
- PC GamerEstablished publication · recorded Sep 21, 2026Thing, is that you? Watch this disembodied AI robot hand 'walk' like a terrible spider from the depths of my nightmares